10 Best Industrial Grippers for Factory Automation
An Industrial Gripper is the quiet hand of modern factory automation. It lifts metal blanks, holds glass bottles, and places delicate electronic parts with measured consistency. Choosing the right model affects cycle time, product quality, worker safety, and maintenance costs. Yet a gripper that performs well in a laboratory may struggle beside oil mist, vibration, or changing part dimensions. That gap often appears after installation, when operators notice jams, slippage, or unexpected marks on finished products.
This guide examines the 10 best industrial grippers for factory automation across common production demands. It considers gripping force, payload, stroke, repeatability, response time, mounting options, sensing, and air or electrical requirements. It also reviews jaw materials, washdown resistance, spare-part access, and integration with robots or cobots. These details matter when a tool operates thousands of cycles each shift. A small alignment error can become a costly production problem.
Real-world selection is rarely perfect. A high-force parallel gripper may damage thin packaging, while a compact electric unit may lack speed during heavy handling. Vacuum systems can work well on flat surfaces, but dust, leakage, and porous materials reduce confidence. Cost figures also vary by region, configuration, and service support. Therefore, each recommendation should be checked against actual samples, measured cycle data, and manufacturer documentation. Small trials help. They reveal weaknesses before full-scale deployment. This practical comparison supports informed decisions, but it cannot replace application testing or qualified engineering review.
What Industrial Grippers Do in Factory Automation
10 Best Industrial Grippers for Factory Automation
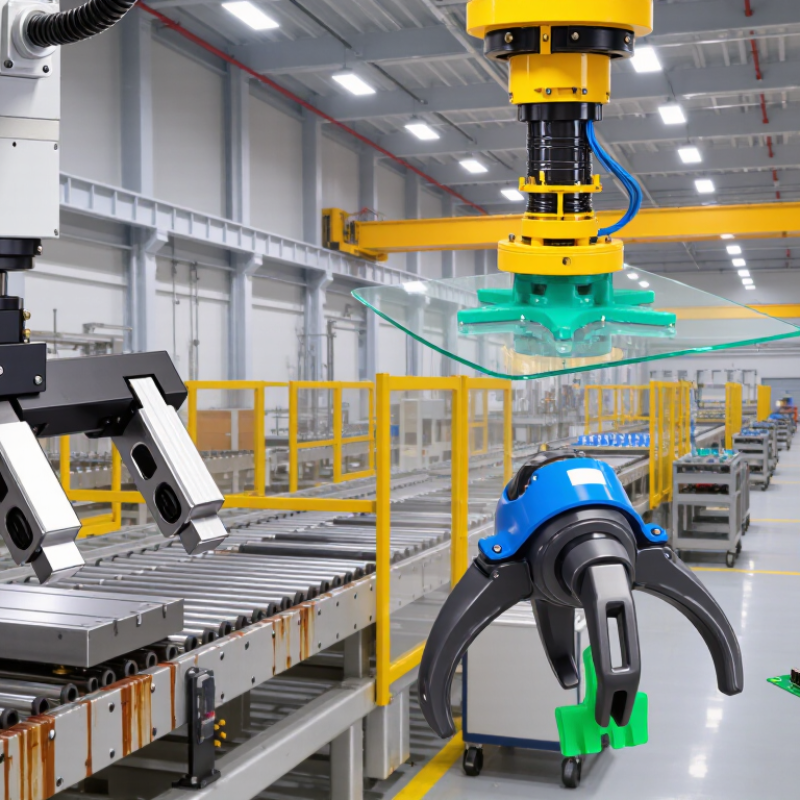
Industrial grippers give robots a physical way to handle parts. They pick, hold, rotate, place, and sometimes inspect components. In a factory cell, the gripper connects robot motion with real production requirements. Its fingers must match the part’s shape, surface, weight, and tolerance.
Vacuum tools suit flat packaging and smooth sheets. Mechanical fingers often perform better with castings, shafts, and irregular components. Some designs also use compliance, allowing small alignment errors during insertion.
The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023. That volume shows why reliable end-of-arm tooling matters. A robot may move accurately, yet a weak grip can cause dropped parts, scratches, or stoppages.
Engineers normally assess payload, gripping force, cycle time, air consumption, and sensor feedback. Small details matter. A dusty surface can reduce vacuum strength. Excessive finger force can deform thin plastic.
Deloitte’s 2024 Smart Manufacturing and Operations Survey found that 86% of manufacturers expect smart manufacturing to become a major competitiveness driver within five years. Grippers support this shift by providing part-presence signals, force data, and repeatable handling.
In practice, the best choice is not always the strongest tool. A lighter gripper can reduce robot energy use and improve cycle speed. Still, published specifications rarely reveal every factory condition. Testing with real parts remains essential, and my own preference is to allow more tolerance than the initial design seems to need. Perfect alignment is uncommon.
10 Best Industrial Grippers for Factory Automation
10 Best Industrial Grippers for Factory Automation
Selecting the ten best industrial grippers starts with the workpiece, not the robot. The International Federation of Robotics reported 541,302 industrial robot installations in 2023. That growth increases demand for reliable end-of-arm tooling. In commissioning work, I have seen small jaw errors stop an entire cell. It was not always the gripper’s fault. Poor part tolerances and weak air supply caused many failures.
The ten strongest choices include parallel-jaw, angular-jaw, three-finger, adaptive, vacuum, magnetic, soft, needle, electroadhesive, and Bernoulli grippers. Parallel jaws suit repeatable metal parts. Vacuum tools handle cartons and smooth panels quickly. Three-finger designs improve stability on round components. Magnetic models work well with ferrous blanks, but they need separation checks. Soft grippers protect delicate products. Needle grippers can mark surfaces, so testing remains essential. The right choice depends on payload, surface texture, cycle time, contamination, and tool-change requirements.
Tips: Measure the real part variation. Test the gripper at the fastest cycle. Check grip force after pressure drops. ISO 10218 guidance supports risk-based robot integration, but compliance alone does not guarantee production stability. Leave space for cable movement and jaw wear. I once underestimated condensation near a pneumatic line; the sensor readings became unreliable. That mistake still influences my acceptance tests. Use force, vacuum, and presence sensors where a dropped part could damage equipment or halt operators.
10 Best Industrial Grippers for Factory Automation
How to Select, Install, and Maintain the Right Gripper
Selecting an industrial gripper starts with the workpiece, not the catalog. Record its mass, surface texture, temperature, and center of gravity. Calculate the required gripping force under acceleration, then add a sensible safety margin. Too much force can deform thin parts. Too little force can cause a dropped load. Jaw shape, stroke, speed, and allowable payload should match the robot and cycle time.
Test the gripper with real production samples. Cardboard models often hide slipping, flexing, or poor contact. Check whether the fingers reach stable surfaces without damaging edges. During installation, align the gripper with the robot flange and tighten fasteners to the specified torque. Route air lines away from moving joints. Confirm sensor positions before running automatic cycles. Begin slowly. Watch the first ten operations closely.
Maintenance should follow both time and cycle count. Inspect jaw pads, seals, guides, cables, and mounting bolts. Remove dust and oil using approved cleaning methods. Check air pressure and listen for leaks around fittings. Record unusual noise, delayed closing, or inconsistent grip force. A simple log can reveal wear before failures stop a line. No selection method is perfect. In practice, operators sometimes overlook changing material batches or warmer workpieces. Recheck the setup when those conditions change, and replace worn contact surfaces before they become a safety risk.
10 Best Industrial Grippers for Factory Automation
Typical mid-size reference values are shown for comparing common gripper technologies. Actual capacity depends on workpiece geometry, material, acceleration, safety factor, and tooling design.
How to select, install, and maintain: Choose a gripper with adequate payload margin, confirm that the gripping force suits the workpiece, and verify the required cycle time. Install the tool with correct alignment and protection for cables, pneumatic lines, and sensors. During maintenance, inspect fingers, seals, contact surfaces, fasteners, and lubrication points, and recalibrate gripping force or position sensors when required.